Motivation
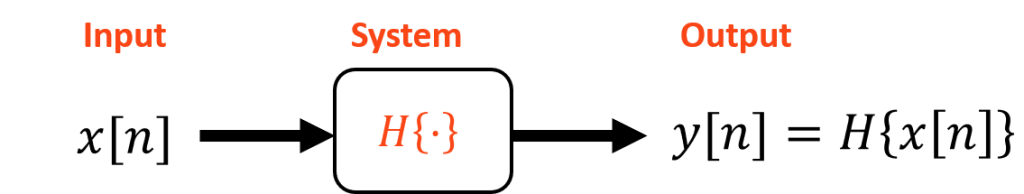
Throughout the course, we will visualize systems using block diagrams, such as the one shown here. Block diagrams are a straightforward way to illustrate the input and output of a system. In our diagram, the  is the input, which the system manipulates, and
 is the output. Mathematically, we represent a system by a function
 that operates on signals. Therefore, the system above can be formally expressed as
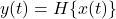 . Note that this notation will disappear when we start focusing on linear, time-invariant in the next class.
Connecting Systems
We can build many new systems by chaining together other systems in series, parallel, and with feedback. Each system is shown here.
When in series, the output of one system becomes the input to the second. For example, applying an “auto-tune” system followed by “reverb” system to an audio signal is an example of systems in series.
When in parallel, we use one input for both systems and then add the outputs together. For example, an audio signals may be applied to “bass boosted” system and “treble boosted” system before being added together to get both enhancements.
When in a feedback configuration, one system modifies the inputs while another system modifies the output of the overall system. The outputs of both systems are then added together and become the output. Placing a speaker near a microphone is an example of a feedback system, where audio is from the microphone is fed back into the microphone.

A series connection is mathematically described by


![y[n] = H_1 \{ x[n} \} + H_2 \{ x[n] \}](https://smartdata.ece.ufl.edu/wp-content/ql-cache/quicklatex.com-4bca5b8d6e962205a1405c7e4b270716_l3.png "Rendered by QuickLaTeX.com")

![y[n] = H_1 \{ x[n} \} + H_2 \{ y[n] \}](https://smartdata.ece.ufl.edu/wp-content/ql-cache/quicklatex.com-5b20d1abdf13fa553a80a23238347d29_l3.png "Rendered by QuickLaTeX.com")
General System Properties
Linear / nonlinear

A system is linear if it obeys the law of superposition. Formally, if is a system with inputs  or
 and outputs
 or
 , such that
 and
 , then the system is linear if

where  and
 are arbitrary scalar numbers. The diagram on the right illustrates equivalence with block diagrams.
Linearity allows us to separate the systems from their individual inputs. A linear system is like the brightness slider on your phone. Every pixel gets brighter by exactly the same amount, regardless of what’s in the picture. A nonlinear system is like an AI cartoon filter. It doesn’t treat every pixel the same—it recognizes faces, eyes, and hair, then changes them differently. The output depends on the content of the image, not just the value of each pixel.
Time-invariant / time-varying

A system is time-invariant if the system does not change with time. Formally, if is a system at time  with input and output , such that , then the system is time-invariant if

for any arbitrary time delay  . That is, if we delay our input, we expect the output to be delayed by the same amount. In a time-invariant system, an input delay may not affect the output signal in any other way. The stock market could you considered time-varying system. Putting money in the stock market today versus tomorrow could be the difference between making or losing money.
Memoryless / with memory
A system is instantaneous (or memoryless) if  is a function of
 at only time n
This is equivalent to stating that
- is not a function of
 for
 (past values)
- is not a function of
 for (future values)
A system that is not memoryless is said to be dynamic or have memory. A system with memory must “remember” previous inputs / future inputs.
Causal / anticausal / acausal
A system H{⋅} is causal (or physical or non-anticipative) if
- is only a function of for
 (past and current values)
A system is anticausal if
- is only a function of for
 (future values)
A system is acausal if
- is a function of for any
 (past and future values)
All real-time systems are causal systems.
Bounded-input, bounded-output (BIBO) stable / unstable
A system is BIBO stable if any amplitude-bounded input (i.e., the signal never reaches or approaches  for all ) yields and amplitude-bounded output (i.e., the signal never reaches or approaches for all ).
Mathematically, this is written as
