The Sifting or Sampling Property
Summary: The sifting property states that we can represent any signal as a weighted sum of shifted impulses, 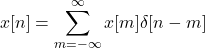
Step 1: Multiplication of Signal and Impulse
First, consider we multiply a signal  by shifted impulse
 , then

is zero everywhere except at time  . Therefore, only the value at
 is expressed in the signal.
Step 2: Express a Constant as Shifted Impulses
Second, consider the sum of shifted impulses

Step 3: Express Any Signal as Shifted Impulses
We can combine the two results above to get


Hence, we sample at every  and then sum the samples together to get back . This is known as the sifting property or the sampling property of an impulse function.
At first glance, this may seem like an exercise in tautology. However, this property is key to understanding linear, time-invariant (LTI) systems.
Deriving the Impulse Response
Summary: The output of any linear, time-invariant (LTI) systems can be expressed as a weighted sum of shifted impulse responses (the system’s output with an impulse input). The weights and shifts are determined by the inputs values, 
Step 1: Start with a time-invariant system
Let the input to a time-invariant system  be an impulse
 . Due to time-invariance, we know that delaying or advancing the impulse will delay or advance the output
 . Hence, we can say
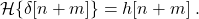
Step 2: Add linearity
To now continue to consider the time-invariant system discussed in the previous subsection. If this system is also linear, we will know what output to expect from a sum of two or more different  inputs. For example, for the input signal
 , the output response would be


Step 3: Extend with the sampling property
In the previous subsection, we showed that linearity allowed us to determine the output from a sum of two different functions. We can extend this idea to a sum of any number of delta functions. Furthermore, the sampling property tells us that we can represent any signal as an infinite sum of amplified delta functions. So, if we now let be the input to the linear, time-invariant (LTI) system , we get
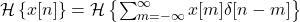
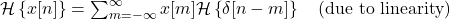


The result of these steps is known as the convolution sum. To find the output, we need to know the input signal and and the impulse response . The function is the response of the system to an single impulse input at time t=0, i.e., .
If an impulse response of a system is infinite in duration, we refer to it as an infinite impulse response system. If an impulse response of a system is finite in duration, we refer to it as a finite impulse response system.
Convolution properties
Commutativity: 
Associativity: 
Distributivity: 
Associativity with scalar multiplication: 
Multiplicative identity: 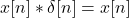
Graphically understanding convolution
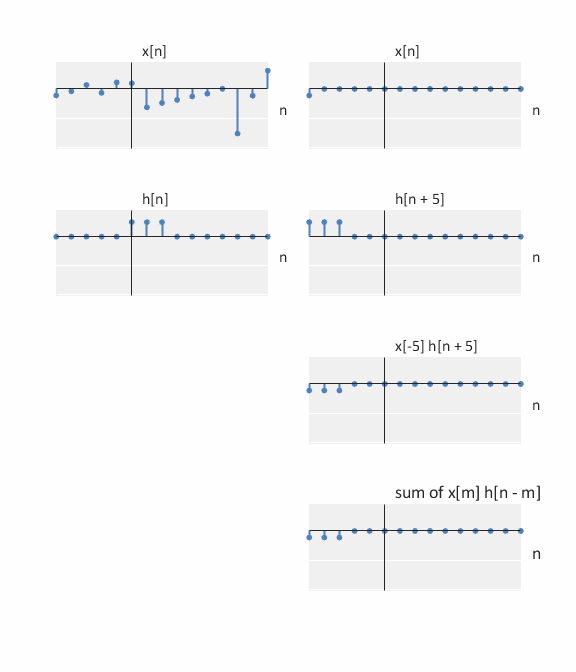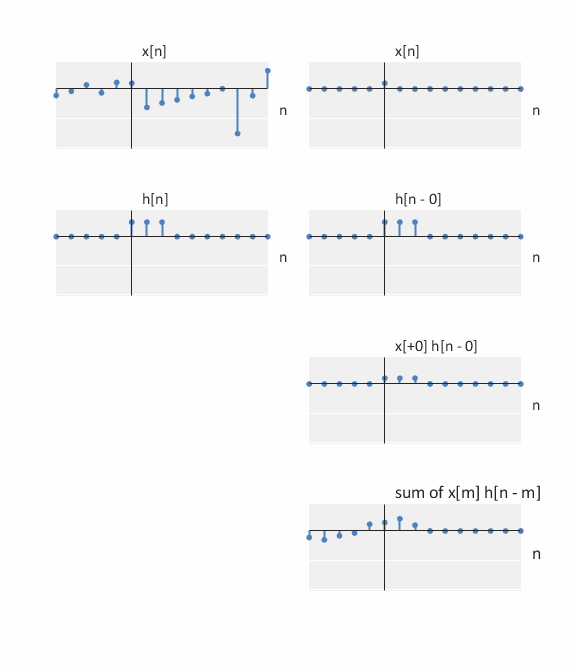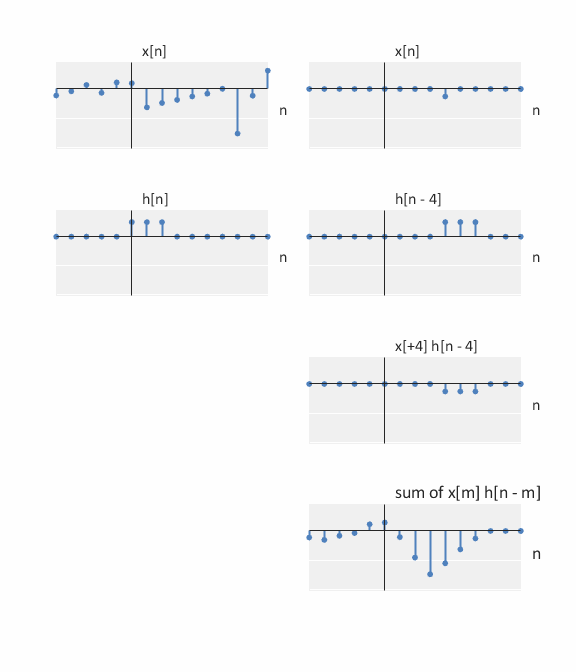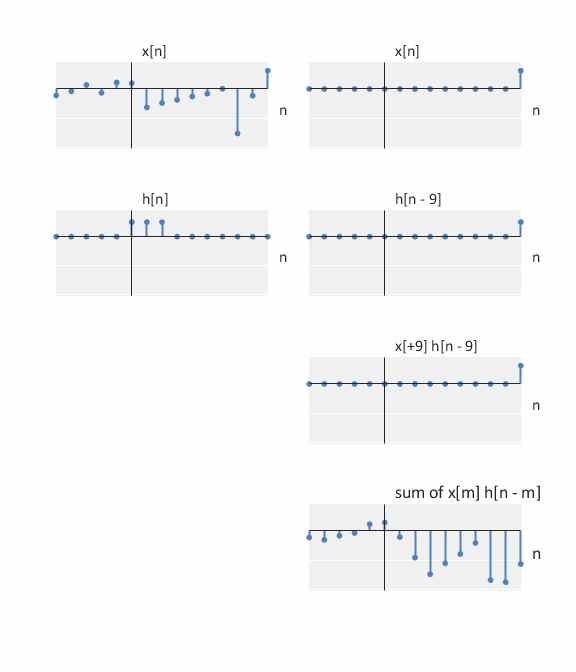
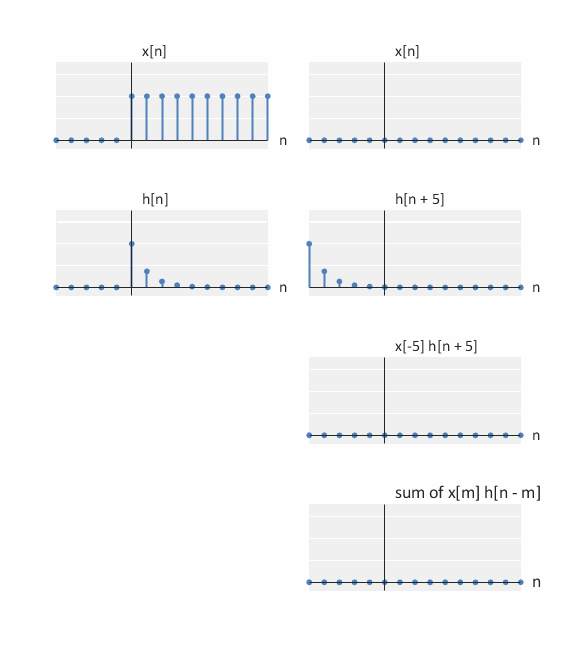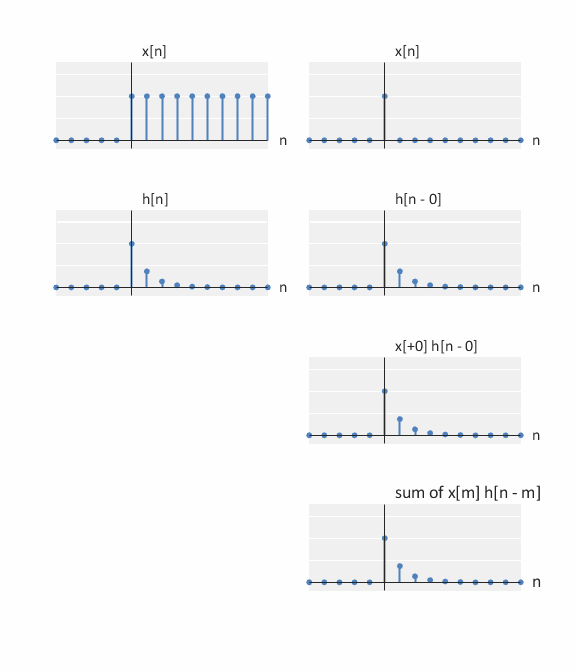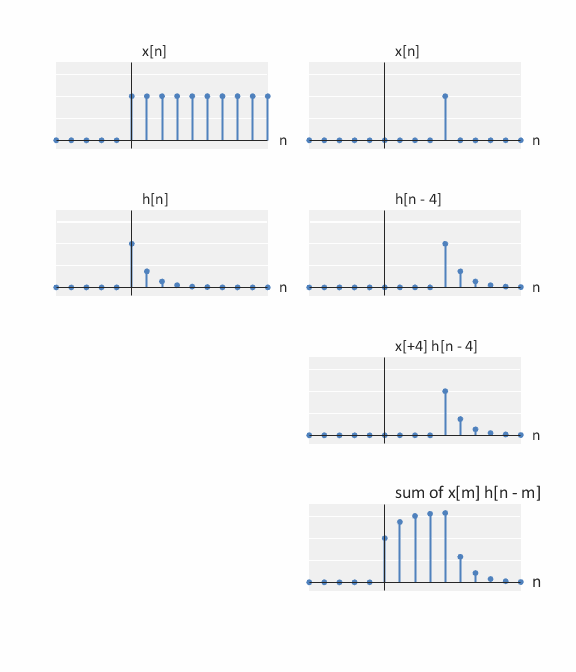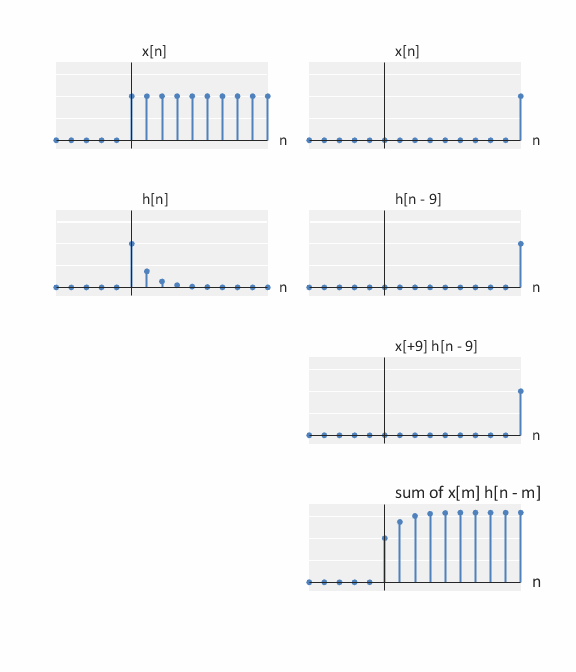
Convolution can be seen as a graphical process:
- Plot
 with dependent variable

- Plot
 with dependent variable (
 reflected around
 ).
- Plot
 with dependent variable (
 can shift from
 (all the way to the left) to
 (all the way to the right).
- For each shift (i.e. ), compute
 (i.e., multiply
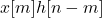 and then sum the result).
Graphical Convolution Examples
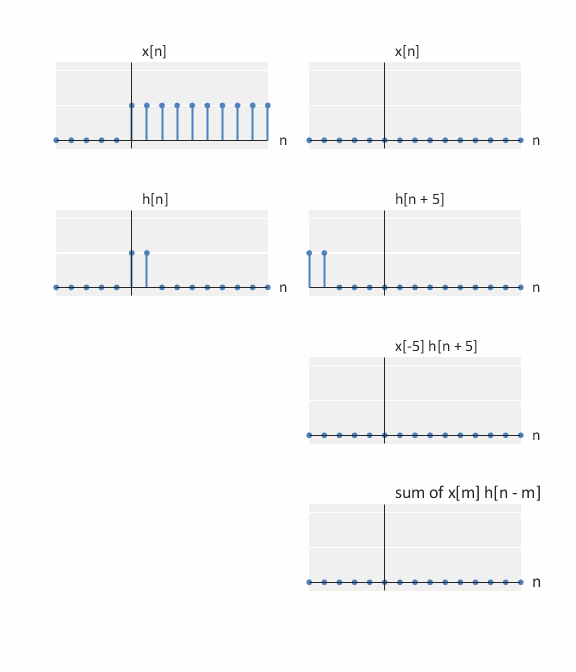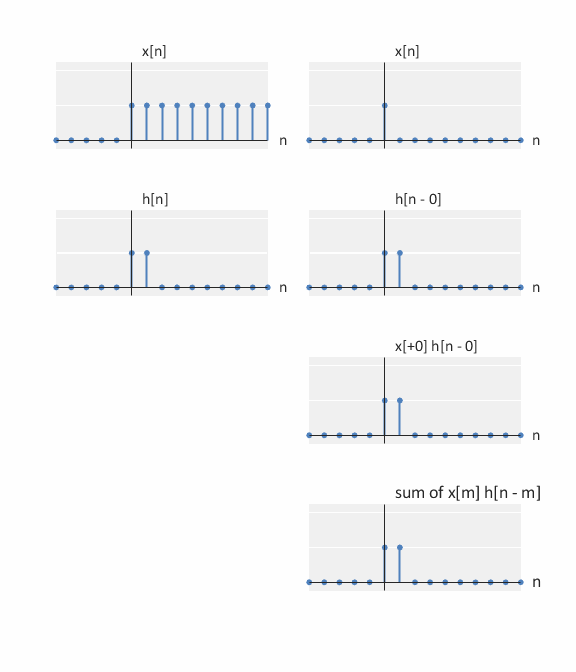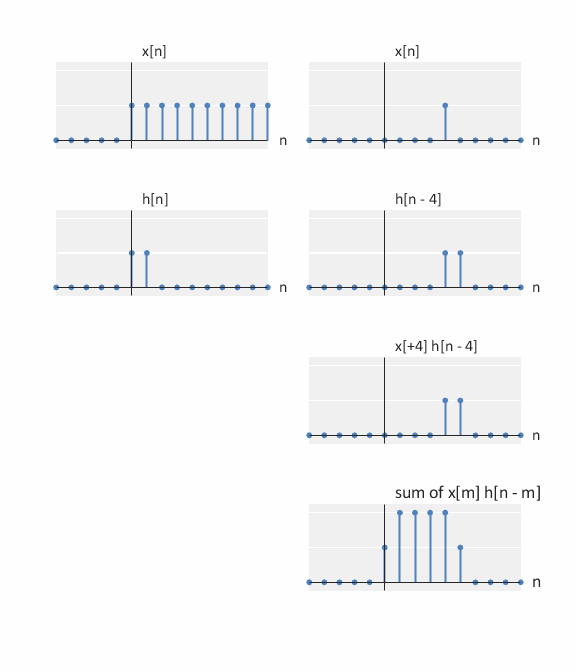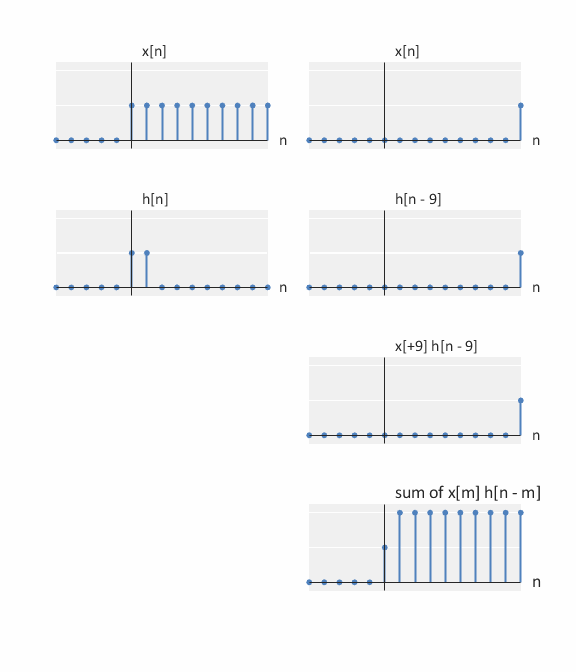
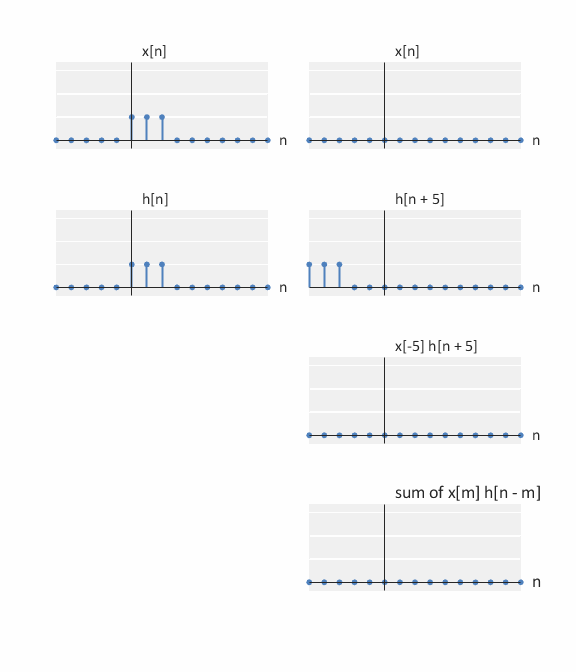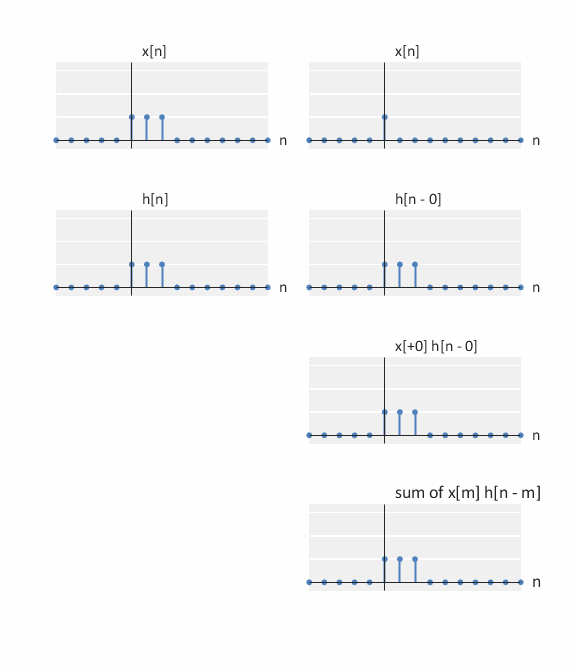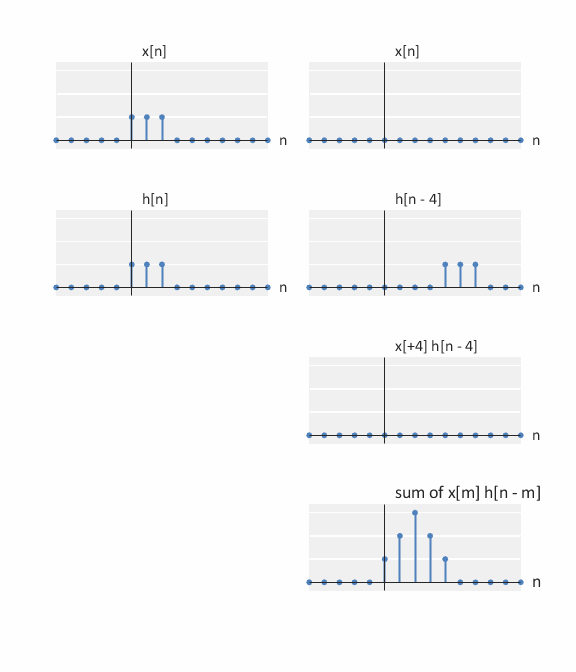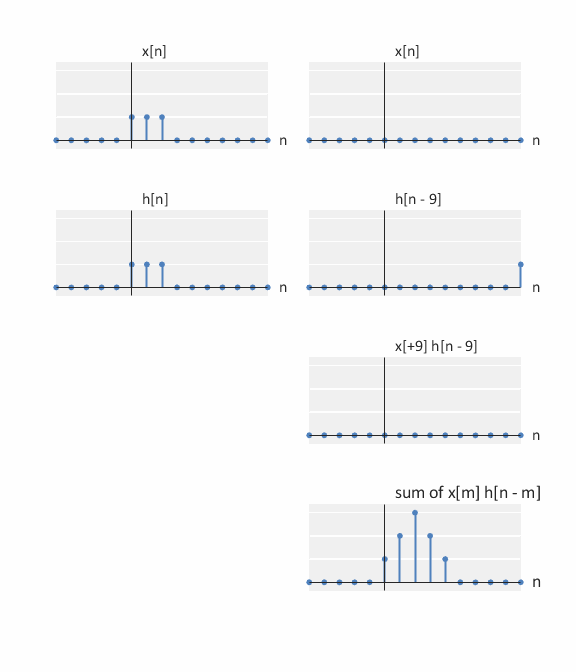
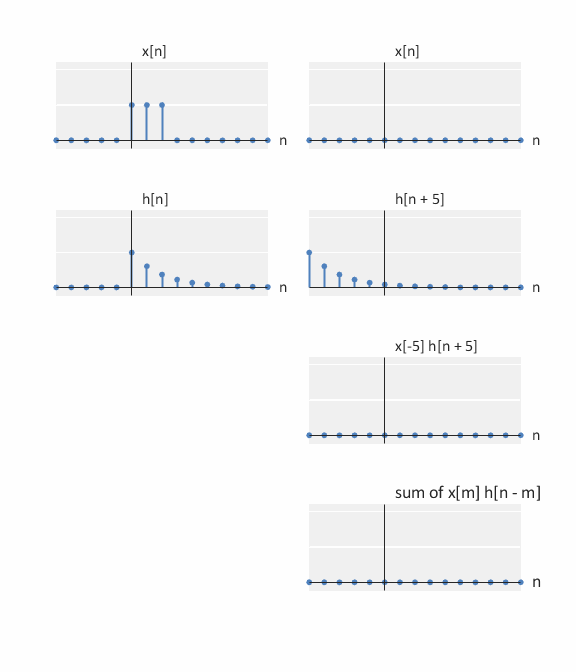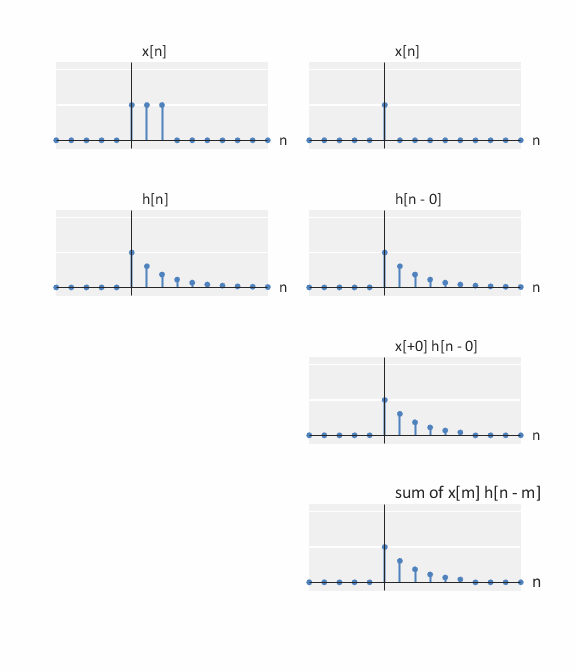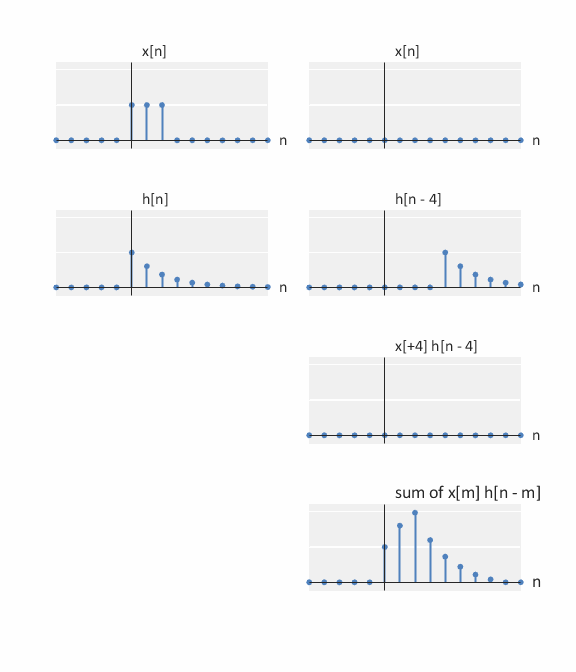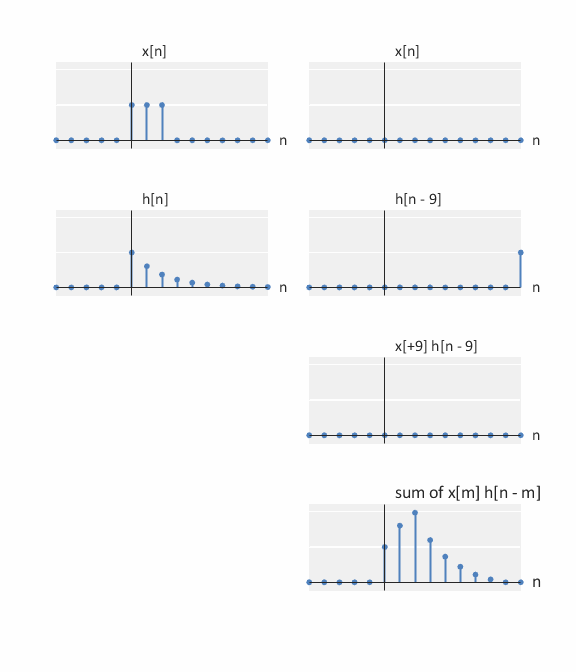
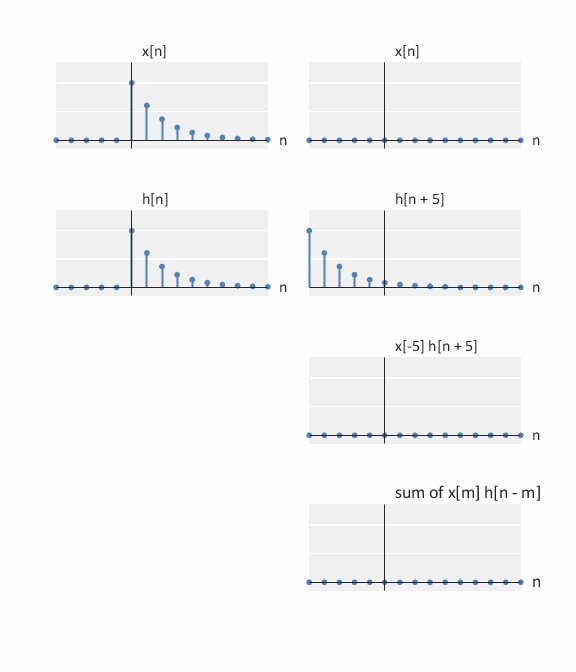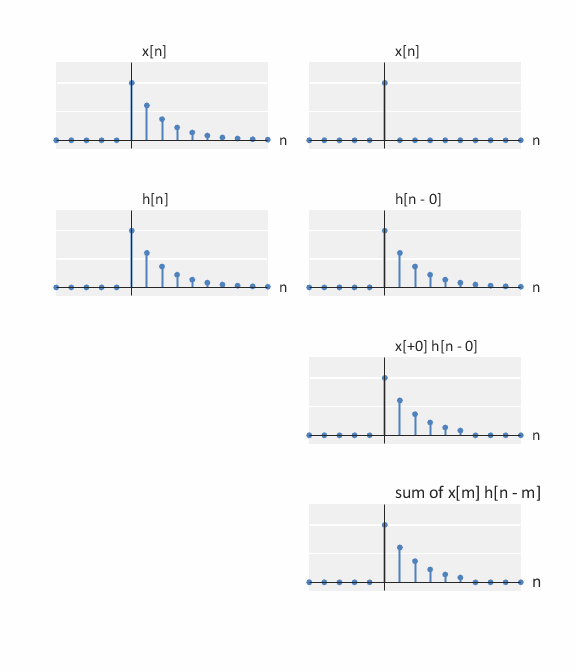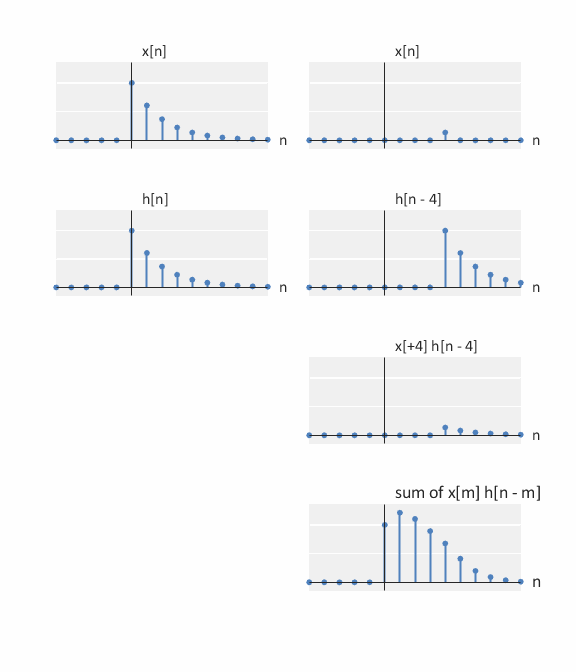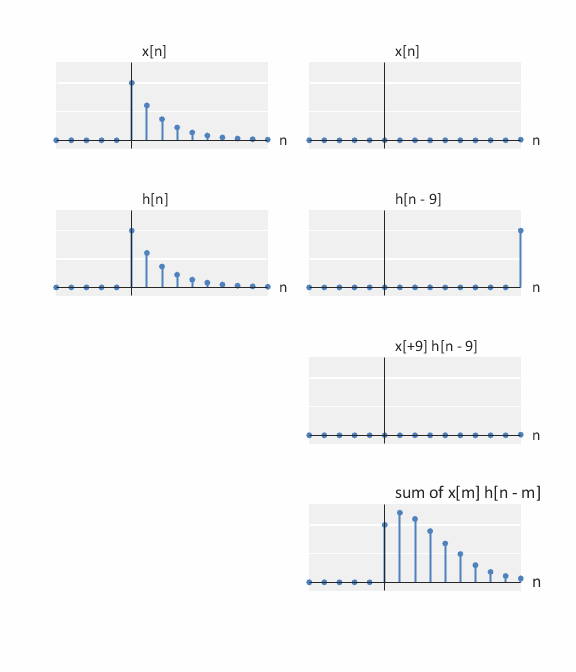
Solving the convolution sum for discrete-time signal can be a bit trickier than solving the convolution integral. As a result, we will focus on solving these problems graphically. Below is a collection of graphical examples of discrete-time convolution.
Box and an impulse


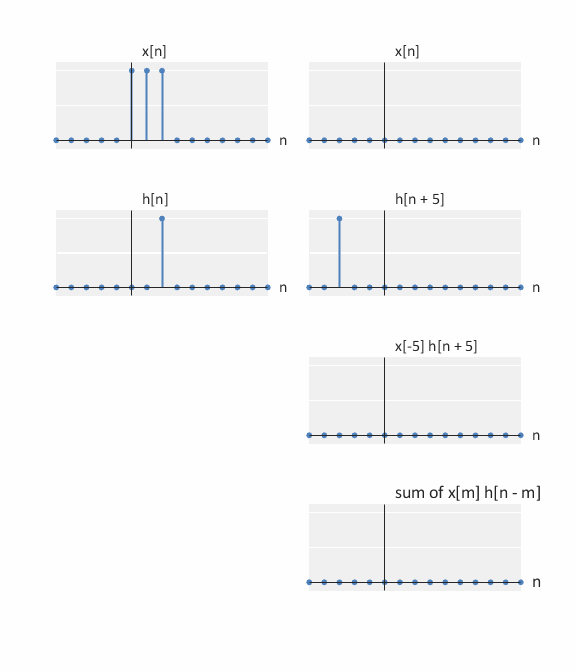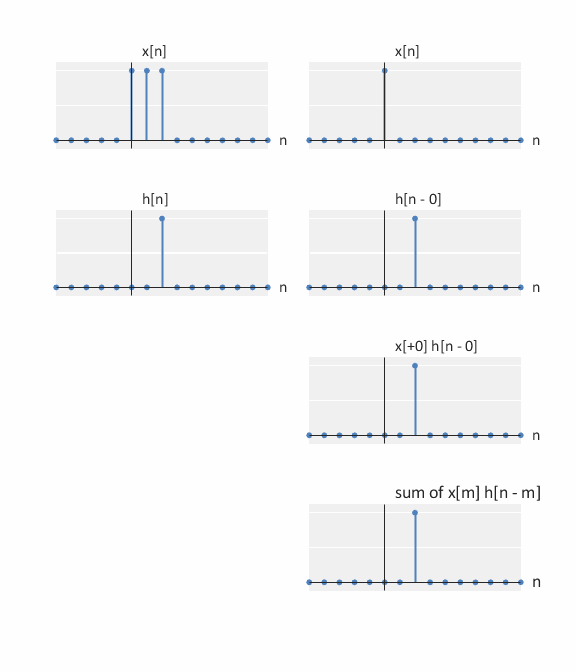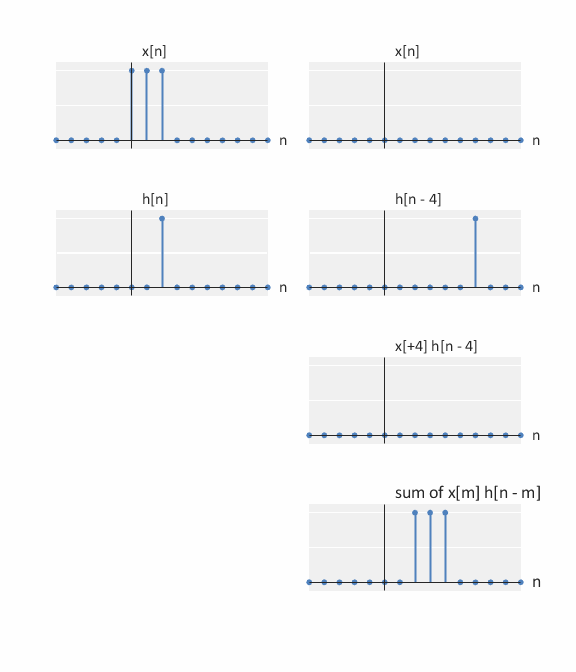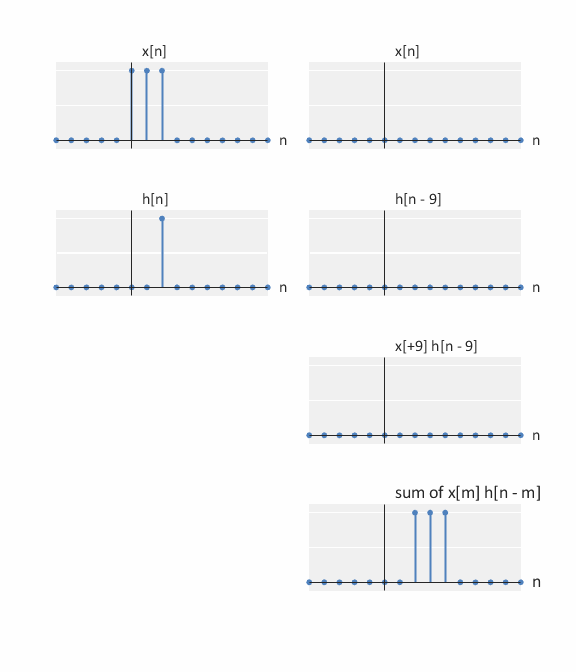
Two boxes

Box and exponential

Two exponentials

Finite Ramp and Box

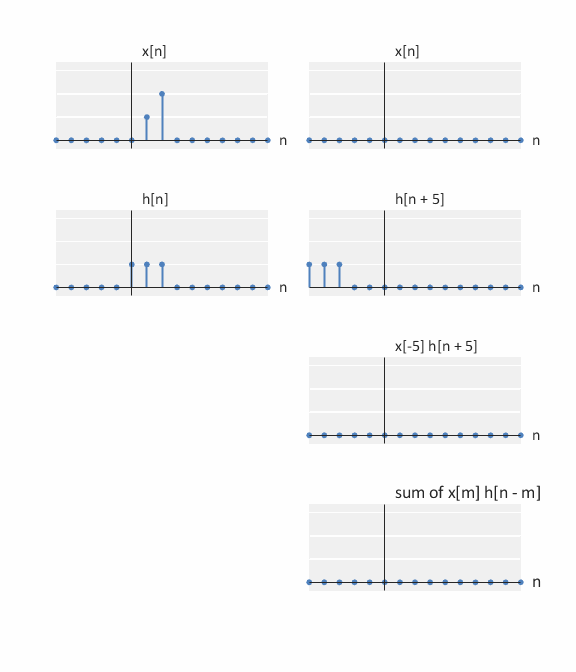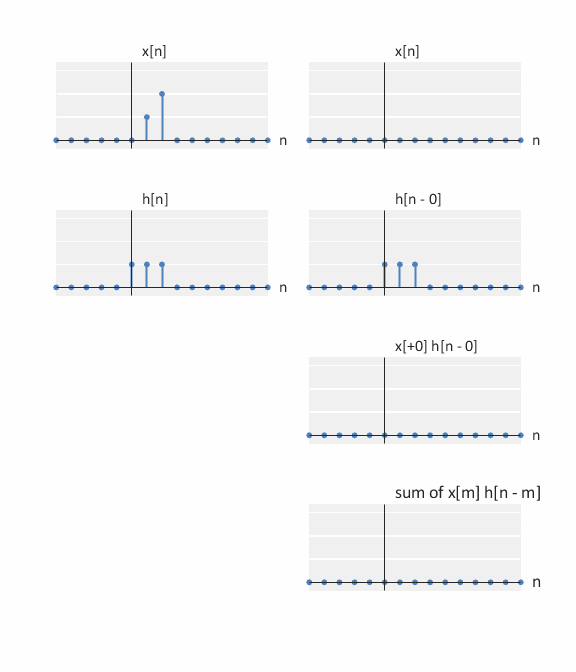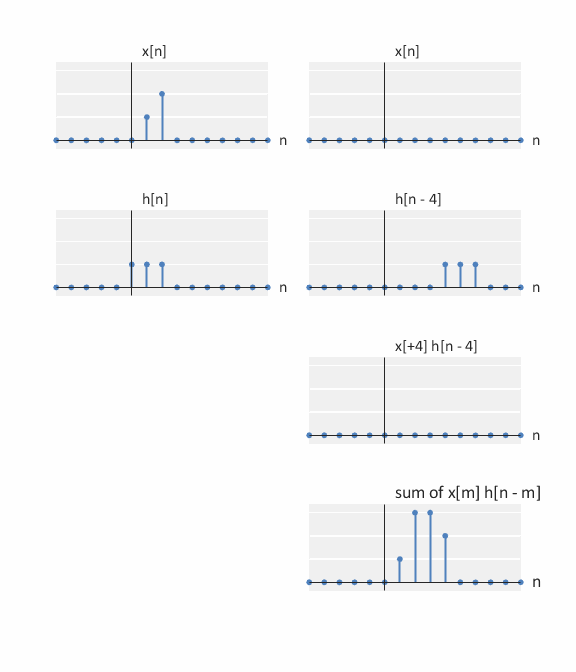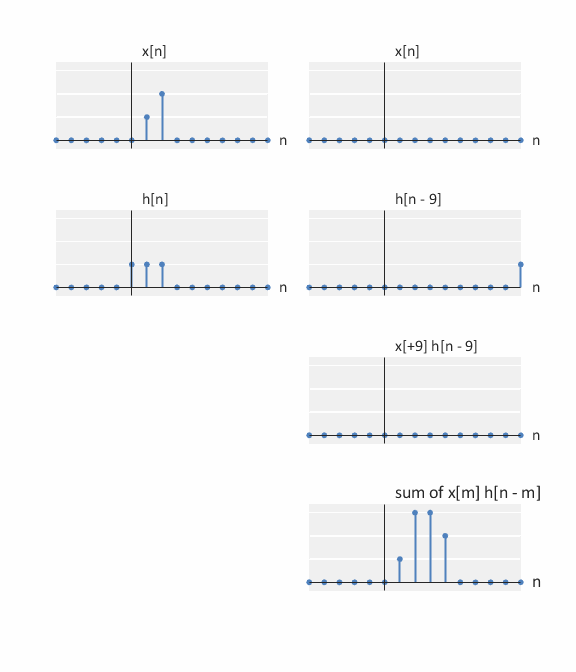
Random Numbers and Box
 random signal
Step function and an exponential

Step function and a box